Links
Abstract
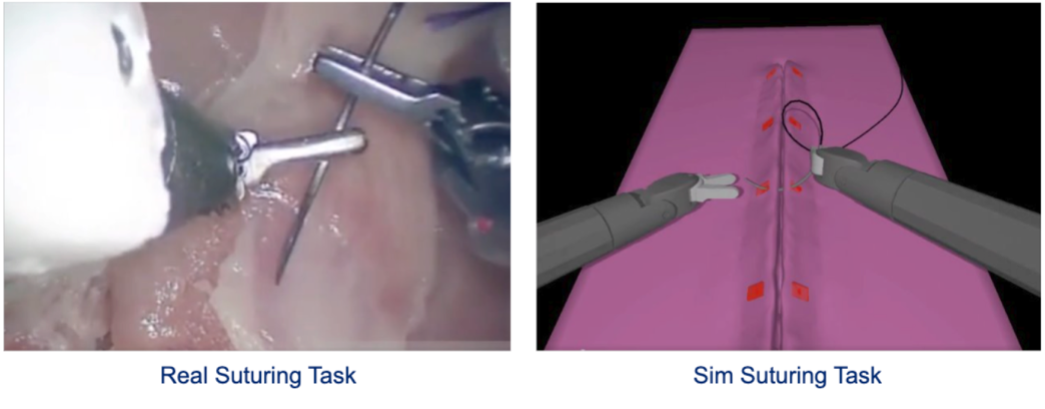
Automating dexterous tasks is challenging because it requires learning a fine-grained, low-level policy that is difficult to explicitly program. Imitation learning (IL) methods represent the current state of the art. We focus on the complex task of suturing, and use the AMBF surgical simulator to develop software for collecting data and training and evaluating IL models for suturing. We also implement a domain randomization pipeline to improve out of domain transferability. Our evaluations show significant improvement via our approach in hold-out simulation environments.
Figure