Links
- 1. General folder
- 2. Motor Chirp Signal
- 3. Motor Chirp figure
- 4. Motor Tracking with video detection, unit test
- 5. DLC Training Evaluation (Tracking performance stats)
Introduction
To investigate active sensing in weakly electric fish, we developed a closed-loop tracking rig. Since these fish naturally seek shelter, we move the cart(refuge) at variable gains relative to the fish’s own movements. By manipulating these gains under varying lighting conditions and other settings, we can learn how the fish uses its electric sense to maintain its position.
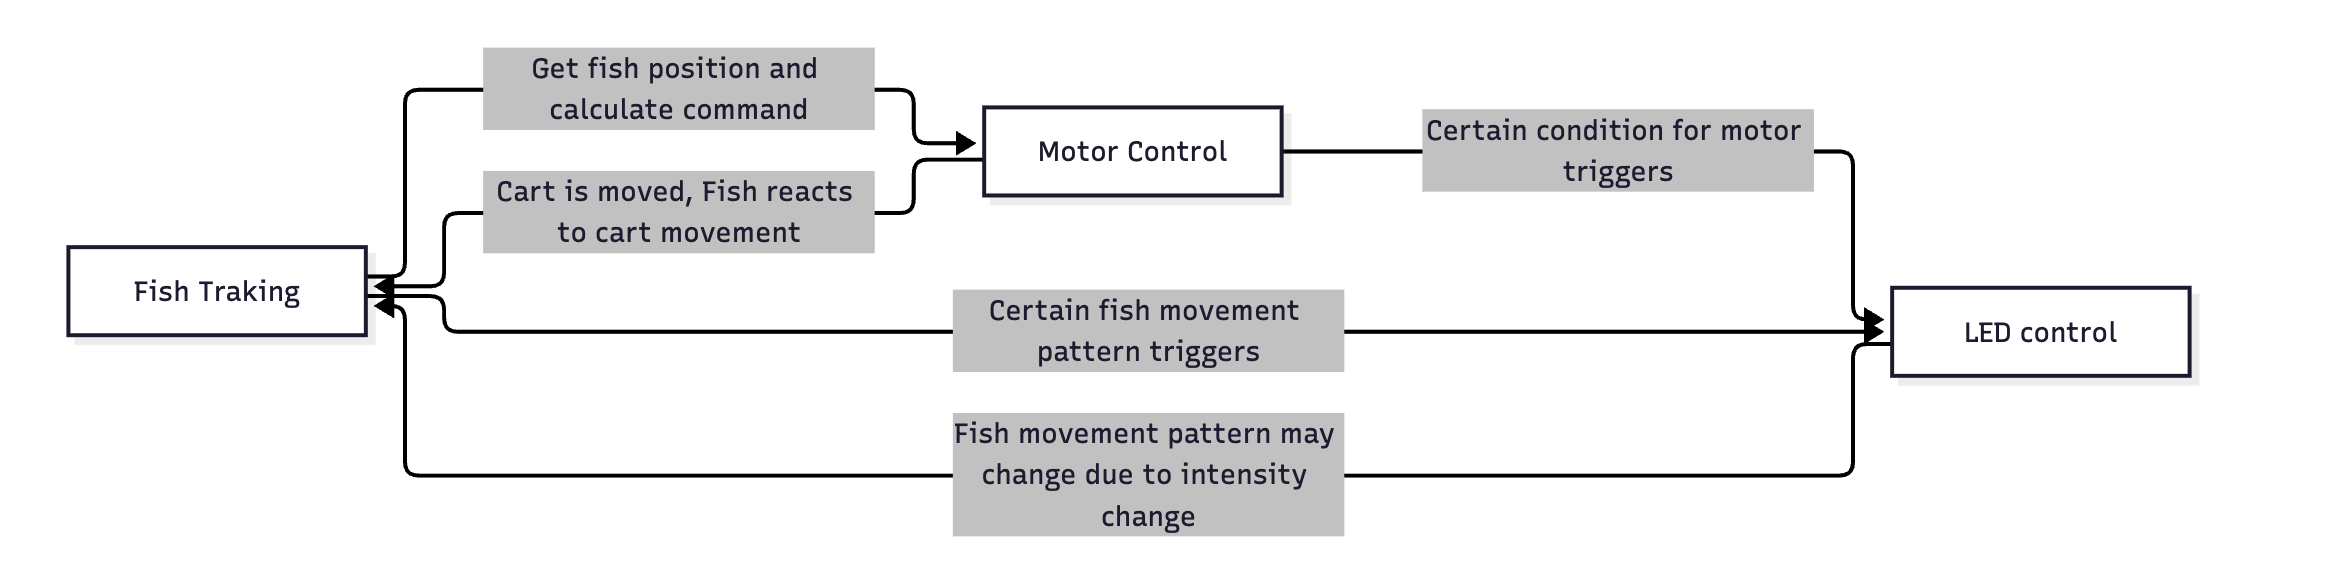 For now, conditions to change the light are under investigation so led are mostly running at constant brightness for now.
III. Required hardware
All hardware has been and will be purchased through LIMBS. Hardware in use:
- PC (I9-9900K, 32G, 2080Ti, Ubuntu 24 LTS without RT kernel)
- Stepnet STP-075-07 Motor Driver.
- Intellidrive BEMA-M45 Stepper Motor, Encoder Set
- PSU for Motor
- Arduino UNO R4 (x3)
- LED Stripe (WS2812B)
- Camera (Genie NANO M1930-NIR)
- Aluminum Rails
- Various connectors for different protocols
- DC power supply (5V 15A)
IV. Deliverables
V.(a) Minimum Deliverables (Completed)
Tracking: A package that is able to track the real fish position from images extracted from fish video or given signal.
hardware interface: Rework the hardware interface package and description to use the Arduino.
V.(b) Expected Deliverables (Completed)
ROS2 Controller package that gets the DLC results, computes an error and sends commands to the arduino (through hardware inteface).
V.(c) Maximum Deliverables (Pending)
Simulation: Same as above + cleanup gazebo package and description. Check camera matches real one and consider using image of a mock fish (TODO see if a fish can be simulated).
V. Timetable
- will be detailed if needed
| Week | Task | Status |
|---|---|---|
| 1-3 | Initialization, Check dependency, Assign Roles | Complete |
| 4 | Test Motor & Camera, find/write suitable driver | Complete |
| 5-7 | Check & Test on LED spec, Motor control, DLC implementaion | 1st Edition complete |
| 8-11 | Finalize LED spec & Node control, Complete whole implementaion | Complete |
| 11-12 | Revising Implementation | Complete |
| 12-TBD | Initial end-to-end experiment, Bug Fixes & Improvement | To be adjusted |
VI. Note
Unfortunately, code cannot be released due to copyrights.