Robot Devices, Kinematics, Dynamics, and Control
Graduate-level introduction to the mechanics of robotic systems with emphasis on the mathematical tools for kinematics and dynamics of robotic systems.
Graduate-level introduction to the mechanics of robotic systems with emphasis on the mathematical tools for kinematics and dynamics of robotic systems.
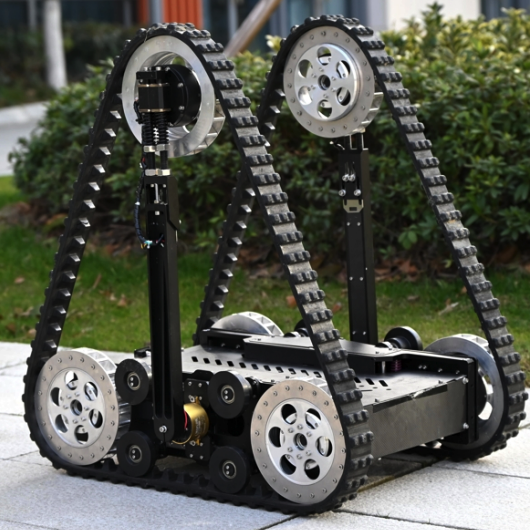
This paper introduces a new design of reconfigurable tracked robots with geometry-changing tracks