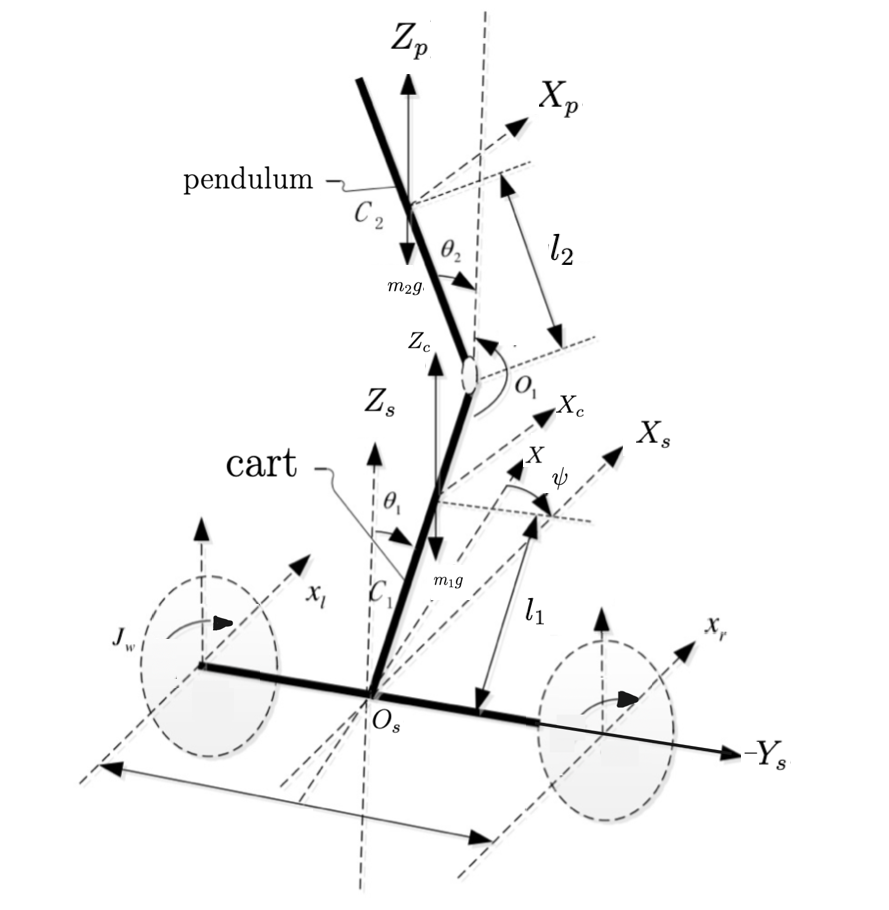
The Design of Controllers for Two-wheeled Self-balancing VehicleBachelor thesis. Hierarchical sliding mode control for an underactuated nonlinear system.